

A free accessibility statement template for the German BFSG law, with legal background, practical tips and sample wording to help avoid costly warning letters.
| Period: | May 2026 - April 2029 |
| Budget: | BMFTR-funded · funding code 16IS26008B |
| Team: | Collaborative project with four partners |
| Industry: | Special-purpose machinery, robotics and industrial automation |
| Area of Application: | Flexible assembly and order picking |




New components regularly present special-purpose machinery builders with the same challenge: finding, designing and testing a suitable gripper and a reliable gripping strategy for the real machine. Today, this work combines extensive experience with time-consuming trial and error.
The ongoing collaborative project Confi-GRIP is developing a web-based software configurator to address this challenge. It is intended to derive suitable gripping strategies and gripper designs from component CAD data and requirements, test them in physics-based simulations and make several solutions comparable. The long-term goal is to reduce the design effort for new assembly and order-picking tasks from weeks to hours.
Confi-GRIP is a research and development project. The platform, models and demonstrators are being developed and validated together with the consortium partners throughout the project.
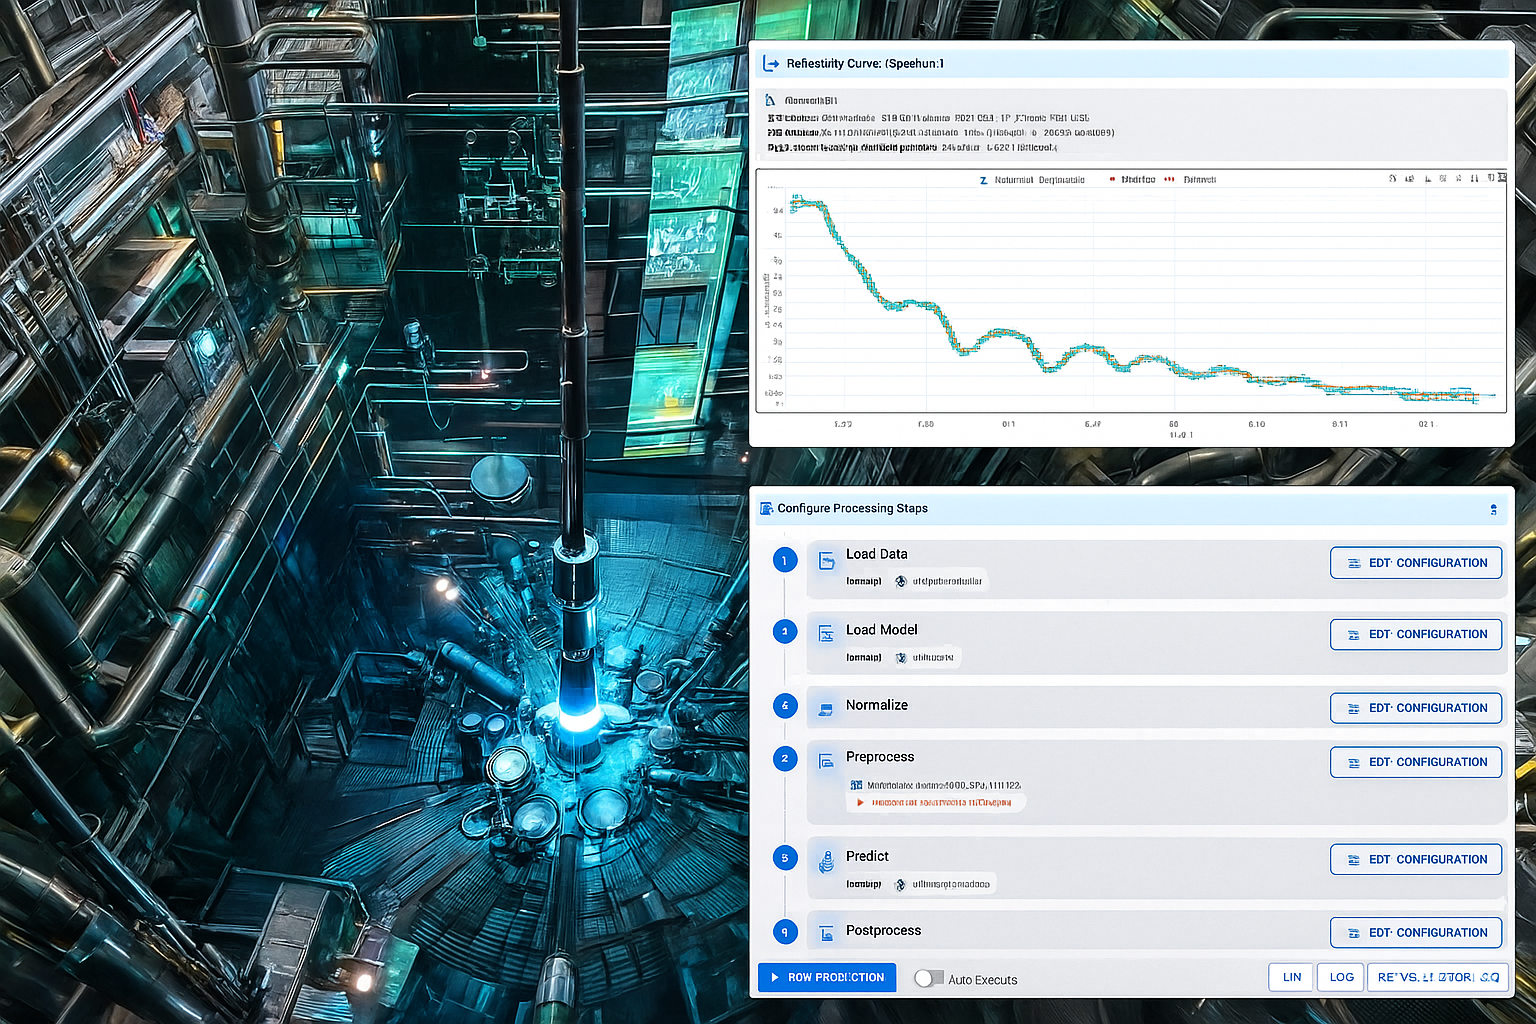
As a consortium partner, Helm & Walter develops the AI and software components that identify the most promising candidates for the computationally expensive physics simulations. We combine machine learning with a user-oriented platform for design and simulation.

We develop surrogate models and other machine-learning methods to select promising gripping and design candidates faster and more reliably.

We are responsible for the APIs and user interfaces controlling grippers and simulations. This includes parameterisation, user guidance and UI/UX for collaboration between people, models and simulations.

We develop data management, the delivery and visualisation of simulation data, and SaaS functionality for the overall platform.
The configurator links four steps: CAD and requirement inputs, AI-supported preselection, physics-based evaluation and a comparable presentation of the results. The computationally expensive simulations can therefore focus on candidates that are particularly promising for the specific application.
Confi-GRIP is being developed by four partners: Hiersemann Prozessautomation GmbH (coordinator), LSA GmbH, Helm & Walter IT-Solutions GmbH and the Fraunhofer Institute for Machine Tools and Forming Technology IWU. Together, they combine expertise in special-purpose machinery, automation, software engineering and scientific simulation.
Funded by: the Federal Ministry of Research, Technology and Space (BMFTR) under the KMU-innovativ: Information and Communication Technologies (ICT) programme.
Funding code for Helm & Walter: 16IS26008B · Funding period: 1 May 2026 to 30 April 2029
The work is carried out as a collaborative research project. The consortium will test the development results with demonstrators and real-world application scenarios.